
Abstract
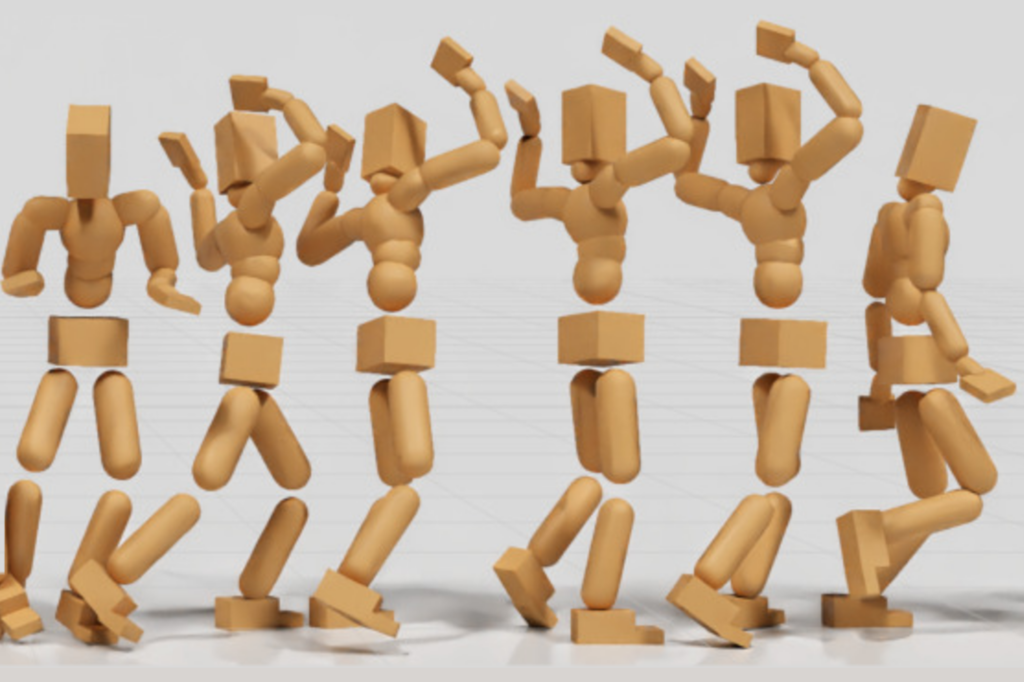
We present a real-time framework for expressive legged locomotion that enables independent control over velocity and style. Unlike existing data-driven controllers, which typically require explicit style labels for training, our method efficiently leverages large-scale unstructured motion data and generalizes to unseen styles. We disentangle style from functional locomotion through a tailored sampling strategy used to train a style encoder whose output conditions an autoregressive diffusion model. During inference, the user provides a style reference clip and a joystick velocity command. The diffusion model then generates a kinematic reference tracked by a reinforcement learning controller. To improve user controllability and stylization strength, we propose an attention biasing mechanism and a velocity command correction strategy. We demonstrate our method on a physics-based humanoid character in simulation and on a physical robot, showcasing robust real-time control and continuous style modulation.
Additional Content
Copyright Notice
The documents contained in these directories are included by the contributing authors as a means to ensure timely dissemination of scholarly and technical work on a non-commercial basis. Copyright and all rights therein are maintained by the authors or by other copyright holders, notwithstanding that they have offered their works here electronically. It is understood that all persons copying this information will adhere to the terms and constraints invoked by each author’s copyright. These works may not be reposted without the explicit permission of the copyright holder.